NYU Team Shares Open-Source Robot Controlled With a Headset
MABEL combines two arms, dexterous hands and a wheeled base. The demonstrations use human control through an Apple Vision Pro headset, not autonomous household operation.
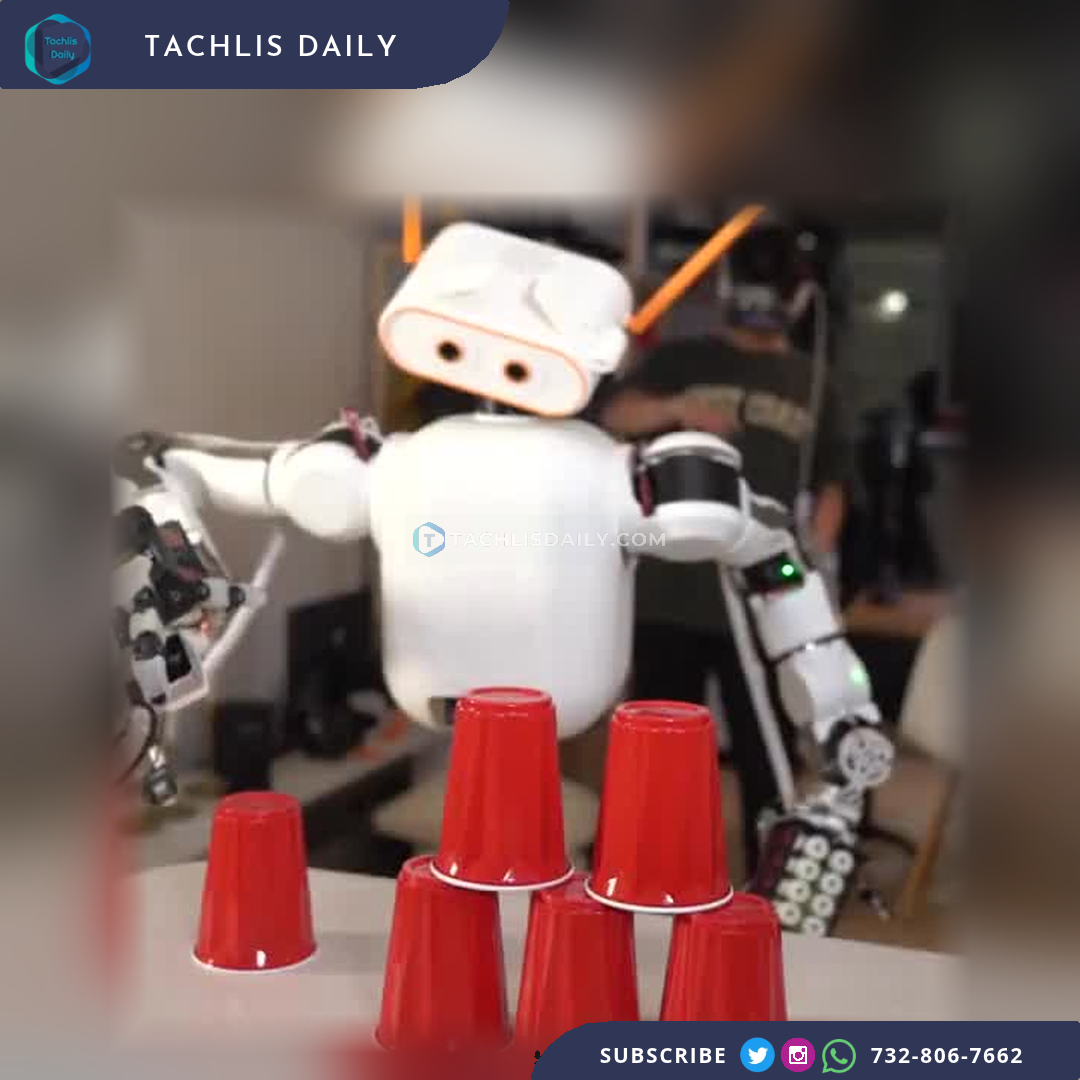
An NYU robotics team has shared MABEL, an open-source mobile robot with two arms, dexterous hands and a wheeled base, along with demonstrations controlled by a person wearing an Apple Vision Pro headset.
The research was posted November 2 and the public files were released November 4. This is a look at that research demonstration, not a new product launch today. The robot is a research platform rather than a ready-to-buy household appliance.
MABEL uses the headset's head and hand tracking to let an operator guide its movements without handheld controllers. The team says its design combines two seven-degree-of-freedom arms, two 17-degree-of-freedom hands, a pitching torso, a lift and a mobile base.
The team describes an end-to-end research workflow that collects data through teleoperation and uses it to train learned policies. That does not make the headset-controlled demonstrations in this video autonomous: a person is directing the robot.
Open source means the team has made designs and software available so others can study, build on or adapt the work under the relevant licenses. It does not mean a physical robot is free. The accompanying montage retains speed labels where footage is accelerated.